
Crawler robots are professional inspection tools made for remote inspection data collection in inaccessible or hazardous environments. They are one part of a wider shift toward robotics for NDT.
These robotic crawlers include pipe inspection robots that travel inside pipelines, magnetic crawlers that move across steel tanks, vessels, and pipes while collecting ultrasonic inspection data, and utility or amphibious crawlers designed for remote inspection in confined and difficult-to-access environments. The right inspection crawler depends on the asset, access conditions, and inspection task.
Other common terms for crawler robots include:
- Robotic crawlers
- Pipe inspection robots
- Inspection crawlers
- Pipe crawler robots
- Crawling robots
Types of Crawler Robots
Crawler robots are selected according to the surface or environment being inspected. Pipe crawlers travel inside pipelines and collect visual inspection footage. Magnetic crawlers attach to ferrous surfaces and support ultrasonic testing. Utility and amphibious robots provide remote access to confined, submerged, or otherwise difficult-to-reach industrial environments.
| Type | What it inspects | Typical payload | Typical access | Example MFE products |
|---|---|---|---|---|
| Pipe and sewer crawlers | Internal pipe surfaces, sewer systems, stormwater systems, and pipelines | Camera systems for visual inspection | Inside pipes; diameter range depends on the model (e.g. 6–12 in. for the DT320 Mini, 6–24 in. for the A-150, 8 in. and larger for the A-200, 50–1,000 mm for the CRAB-ROBOT) | Pipe Trekker A-150, Pipe Trekker A-200, Deep Trekker DT300 Series Package, Endo Control CRAB-ROBOT, Deep Trekker DT320 Mini, Deep Trekker DT340 |
| Magnetic crawlers | Ferrous pipes, elbows, tanks, vessels, and other steel surfaces | Ultrasonic thickness measurement, corrosion mapping, and encoded B-scan collection | External ferrous surfaces, flat or curved (e.g. the HSR scans pipe down to 2 in. nominal diameter; the JIREH TRIPOD travels circumferentially on pipe from 8 in. OD) | MFE HPX Wall Crawler, JIREH TRIPOD Magnetic Crawler, MFE HSR Crawler |
| Utility and amphibious crawlers | Confined spaces, utility tunnels, pipelines, submerged infrastructure, and water tanks | Visual cameras and, where supported, specialized inspection or cleaning attachments | Ground-based access, confined environments, and submerged environments, depending on the product | Deep Trekker ONYX UGV, Deep Trekker DT640, Teledyne FLIR SUGV 325 |
Crawler Robot Rentals and Sales
The crawler robots below are grouped by inspection type: pipe inspection robots, magnetic crawlers for steel tanks, vessels and walls, and utility and amphibious robots. Each robot crawler card links to its product page for full specifications.
Pipe Crawlers
1. Pipe Trekker A-150 Pipe Inspection Robot
The Pipe Trekker A-150 is a portable pipe crawler designed for sewer pipe inspections in pipes ranging from 6 to 24 inches in diameter. Its high-definition pan/tilt camera, weatherproof controller, and motorized lift arm support visual inspections of municipal and industrial pipelines.
The crawler also features modular rubber wheel kits, floodlights, and a 512 Hz sonde for locating the crawler and identifying anomalies.
Learn more about the Pipe Trekker A-150
2. Pipe Trekker A-200 Pipe Inspection Robot
The Pipe Trekker A-200 is a pipe inspection crawler designed for larger-diameter pipes. Its configuration includes a robust camera system, multiple wheel options, and an extended tether for inspection work across different pipeline environments.
It handles 8-inch and larger pipes, and offers real-time video and non-destructive testing for industrial and municipal pipeline inspections.
Learn more about the Pipe Trekker A-200
3. Deep Trekker DT300 Series Pipe Crawler Robot Package
The Deep Trekker DT300 Series Package combines two pipe crawlers, the DT340 and DT320, with a shared controller and powered tether reel. This dual-crawler pipe inspection system is designed to cover different pipe diameters without requiring two separate complete systems.
The battery-operated package includes submersible cameras, wheel kits, and track sets. Its powered tether reel has a 400-meter capacity, and the system supports up to 8 hours of continuous inspection.
Learn more about the Deep Trekker DT300 Series Package
4. Endo Control CRAB-ROBOT Crawlers
The Endo Control CRAB-ROBOT is a family of pipe inspection crawlers available in different sizes and camera configurations. Its six spring-loaded motor drive arms and rubber-coated wheels help maintain traction and center the robot inside piping, including on uneven surfaces.
Camera head options include forward-view, pan-tilt, and pan-tilt-zoom cameras. The CRAB-ROBOT crawlers are designed for pipes from 50 mm to 1,000 mm in diameter and can navigate tight bends (as small as 0.8x D) and travel vertically within pipelines.
Learn more about the Endo Control CRAB-ROBOT Crawlers
5. Deep Trekker DT320 Mini Pipe Crawler
The Deep Trekker DT320 Mini is a portable, battery-operated pipe inspection crawler designed for pipes ranging from 6 to 12 inches in diameter. Its handheld controller and compact carrying case support stormwater and wastewater inspections without topside power.
The DT320 Mini offers camera pan and tilt, configurable wheel or track options, and compatibility with the DT340 tether and control console. The XL package also includes a powered reel with on-screen distance feedback.
Learn more about the Deep Trekker DT320 Mini Pipe Crawler
6. Deep Trekker Pipe Crawler DT340
The Deep Trekker DT340 is a battery-operated pipe crawler designed for municipal and service-company inspections of water and sewer pipes. It is depth rated to 50 meters (164 ft) and uses steerable wheels to navigate around or over obstacles.
The system includes a lightweight handheld control console, tether, and integrated monitor for viewing CCTV footage. Available configurations include camera options and wheel or track packages for different pipe inspection requirements.
Learn more about the Deep Trekker Pipe Crawler DT340
Magnetic Crawlers for Tanks, Vessels, and Walls
Magnetic crawlers travel across ferrous surfaces to support remote inspection of tanks, vessels, pipes, and other steel assets. Depending on the system, they can collect ultrasonic thickness measurements, corrosion maps, and encoded B-scan data. These inspection crawlers are useful when manual scanning would require additional access equipment or expose inspectors to difficult working conditions.
1. MFE HPX Wall Crawler

The MFE HPX Wall Crawler is a magnetic ultrasonic testing crawler designed for remote inspection of tanks, vessels, walls, and other large vertical assets. Its rare earth magnet motors provide magnetic adhesion, while a sealed position encoder supports B-scan applications.
At 12.5 lb, the HPX provides high-resolution data for corrosion and thickness measurements and is a safer, more efficient alternative for tank wall and roof inspections.
Learn more about the MFE HPX Wall Crawler
2. JIREH TRIPOD Magnetic Crawler

The JIREH TRIPOD is a remotely operated magnetic crawler for weld and corrosion inspection on ferrous pipes, elbows, vessels, and tanks. Its three-wheel drive system maintains contact with curved surfaces while allowing inspectors to position ultrasonic probes remotely.
The system supports corrosion mapping, ultrasonic thickness measurement, encoded B-scan collection, and longitudinal and circumferential weld inspection.
Learn more about the JIREH TRIPOD Magnetic Crawler
3. MFE HSR Crawler
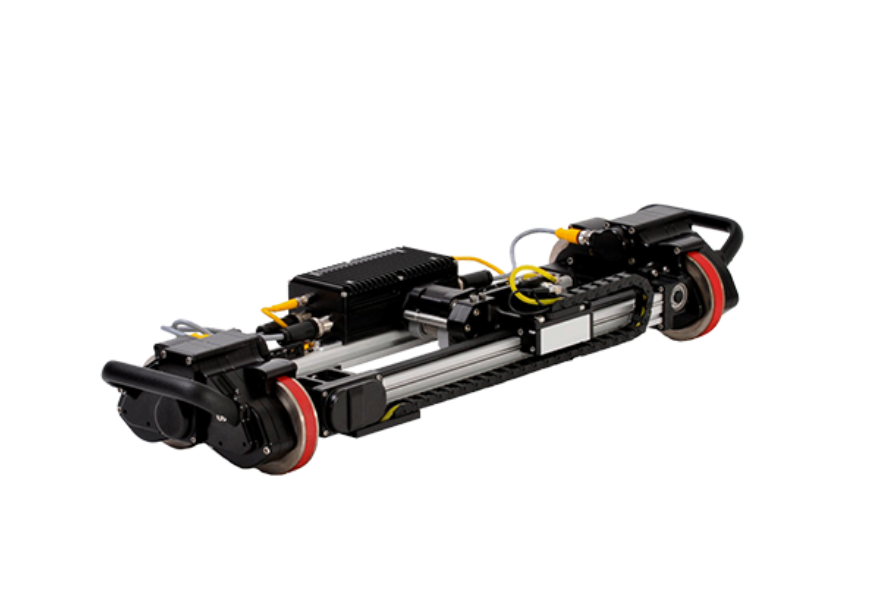
The MFE HSR Crawler is a high-speed raster ultrasonic scanner designed for large vessel inspections. It supports corrosion scanning on pipes as small as 2 inches in diameter without requiring probe adjustments.
Its direct-coupled four-wheel drive, custom-engineered gearing, and robust environmental sealing are designed for operation in demanding industrial inspection environments.
Learn more about the MFE HSR Crawler
Utility and Amphibious Crawlers
Utility and amphibious ground robots provide remote access to confined spaces, underground infrastructure, submerged assets, and other difficult inspection environments. Their configurations vary: some emphasize visual inspection and mobility, while others support underwater inspection and cleaning attachments.
1. Deep Trekker ONYX UGV
The Deep Trekker ONYX UGV is a fully submersible uncrewed ground vehicle designed for remote inspection in confined spaces, underground tunnels, and hazardous industrial environments. Its all-terrain rubber tires and high-clearance frame support movement over debris and uneven surfaces.
The ONYX features an integrated camera system with up to 4K recording, LED lighting, and a weather-resistant handheld controller with a 7-inch LCD display. Its platform also supports third-party payloads and sensors for specialized inspection tasks.
Learn more about the Deep Trekker ONYX UGV
2. Deep Trekker DT640
The Deep Trekker DT640 is a three-wheeled utility crawler designed for underwater inspection and cleaning of tanks and submerged structures. Its modular design supports cleaning attachments, including a vacuum head for sediment removal and a pressure washer for cleaning surfaces underwater or at vertical angles.
The DT640 can also be configured with a Cygnus ultrasonic thickness gauge attachment for spot-checking areas of interest on ship hulls and other structures.
Learn more about the Deep Trekker DT640
3. Teledyne FLIR SUGV 325 Tracked Inspection Robot
The Teledyne FLIR SUGV 325 is an unmanned ground vehicle designed for remote inspection in hard-to-reach areas. Its tracked chassis and articulating flippers help it navigate stairs, slopes, and obstacles, while its onboard visible, thermal, and stitched 360-degree cameras give operators multiple ways to assess its surroundings remotely.
The SUGV 325 can support remote inspection of utility tunnels, pipelines, underground infrastructure, and industrial process areas. Its modular payload architecture also accommodates optional equipment, including a 5-DOF manipulator for remote object handling.
Learn more about the Teledyne FLIR SUGV 325
How to Choose a Pipe Inspection Crawler
Choosing a pipe inspection crawler starts with the pipe itself and the inspection information you need to collect. Pipe diameter, access conditions, run length, water or wastewater conditions, camera requirements, and reporting needs all affect which crawler is appropriate.
Pipe Diameter and Crawler Size
Start by identifying the pipe diameter range you need to inspect. A crawler must fit through the pipe and have sufficient clearance to navigate its interior. Consider the smallest diameter along the inspection route, not just the nominal diameter of the pipe.
For example, the Pipe Trekker A-150 supports pipes from 6 to 24 inches, while the Deep Trekker DT320 Mini is designed for pipes from 6 to 12 inches. Other crawlers support different pipe sizes and configurations.
Run Length and Tether Management
Consider the distance the crawler must travel and how its tether is managed. Tether length, reel configuration, and the ability to retrieve the crawler all affect deployment planning. Some systems offer powered reels, while others use manual tether management.
Camera and Lighting Requirements
Determine what the inspection camera needs to show. A forward-facing camera may be sufficient for basic visual assessment, while pan, tilt, and zoom capabilities can help operators examine specific areas and view different parts of a pipe. Lighting is also important in enclosed or submerged environments.
For some applications, the inspection requirement may involve more than visual footage. Magnetic ultrasonic testing crawlers support a different workflow, collecting thickness and corrosion data from accessible ferrous surfaces.
Wet, Dry, and Sewer Inspection Conditions
Identify whether the crawler will operate in dry pipes, stormwater systems, wastewater infrastructure, or submerged environments. Check the specific product’s operating and depth ratings rather than assuming all pipe crawlers support underwater operation.
Lateral Launch and Access Requirements
Consider how the crawler will enter the inspection area and whether the project requires access through a lateral connection or another restricted entry point. Confirm that the crawler’s dimensions and configuration are appropriate for the planned deployment.
Inspection Recording and Reporting
Consider how inspection footage and measurements will be recorded, reviewed, and incorporated into maintenance records. Some packages include reporting software: the Pipe Trekker A-150 X, for example, integrates with NASSCO PACP software, and the DT320 Mini integrates with most sewer inspection software. Check compatibility with the reporting workflow your team uses.
When a Push Camera May Be a Better Fit
A crawler robot is not necessary for every pipe inspection. A push camera may be more appropriate for smaller or shorter inspections where a wheeled or tracked robot is not needed. Compare the access requirements, inspection distance, camera capabilities, and data needs before choosing between a crawler and a push camera system.
Magnetic Adhesion and Ultrasonic Testing for Steel Assets
For steel pipes, tanks, and vessels, consider whether the inspection requires ultrasonic thickness measurements or corrosion mapping rather than internal visual footage. Magnetic crawlers can carry or position ultrasonic inspection equipment on ferrous surfaces. See MFE’s information on ultrasonic testing for additional context.
How to Use a Crawler Robot
A crawler robot uses a combination of mechanical, electronic, and software systems to navigate and perform tasks in various environments, the majority of which are inaccessible or hazardous for humans.

Initially, the inspection crawler is deployed into the area you want to inspect, where its movement is controlled remotely. Equipped with professional inspection cameras or ultrasonic sensors, depending on the system, it captures real-time data or images of its surroundings remotely while the inspector stands at a safe distance.
As inspection data is transmitted back to the operator they analyze the condition of the area being inspected, identifying potential issues and navigating the crawler to specific locations for closer examination. Inspection data is also being recorded, and can be reviewed after the crawler returns for closer analysis.
This short step-by-step covers how inspectors use crawlers in their work:
- Deployment. The robotic crawler is placed in the starting location.
- Remote control. Operators guide the crawler robot using remote controls, often from a safe distance.
- Data collection. Cameras or sensors on the crawler robot gather visual footage or measurement data.
- Transmission. Data is sent back to the operator for analysis.
- Analysis. The operator assesses the data to make informed decisions or take further action, both live in the field and after the data is collected.
After analyzing the data from the crawler, operators can make decisions regarding maintenance, safety measures, or further inspection needs, ensuring efficient management of infrastructure, facilities, or other areas of interest.
Customizing Your Crawler Robot for Specific Tasks
Crawler configurations can vary according to the inspection environment and the information an operator needs to collect. Before selecting a system, identify which components are included, which are optional, and which require a separate accessory or payload.
Common configuration considerations include:
- Camera systems. Camera options may include forward-facing, pan-tilt, or zoom capabilities, depending on the crawler and configuration.
- Manipulator arms. Some ground robots support optional manipulators for remotely handling objects. Confirm that the specific platform supports the required attachment.
- Inspection instruments. Certain crawler systems support ultrasonic testing equipment for thickness measurements or corrosion inspection. Magnetic UT crawlers are a separate category from camera-based pipe inspection crawlers.
- Lighting. Lighting systems help operators view inspection areas where ambient light is limited. Available lighting depends on the product and configuration.
Check the manufacturer’s documentation for the exact equipment, accessories, and capabilities included in a proposed configuration.
Choosing the Right Tracks for Your Inspection Crawler
Track and wheel configurations affect how an inspection crawler moves through its operating environment. The appropriate configuration depends on the crawler design, surface conditions, available clearance, and inspection requirements.
When comparing options, consider the manufacturer’s guidance on compatible wheel or track assemblies, traction, surface contact, and operating conditions. Some pipe crawlers offer interchangeable wheel or track configurations, but available options vary by model.
For example, the Deep Trekker DT340 X package includes tracks for large-diameter stormwater pipes and culverts, and the DT320 Mini can be fitted with different wheel and track options.
The Top 5 Uses for Crawler Robots
Industrial crawler robots help inspection teams collect visual or measurement data from assets that are difficult to access directly. Their applications depend on the crawler type, inspection equipment, and operating environment.
1. Sewer and Stormwater Pipe Inspection
Pipe inspection crawlers travel through sewer, drainage, and stormwater systems to collect internal visual footage. Operators can use the recorded information to assess pipe conditions and identify areas requiring closer examination or maintenance.
Pipe crawler applications include municipal sewer lines, drainage pipelines, stormwater infrastructure, and culverts.
2. Oil and Gas Pipelines and Process Piping
Remote inspection robots can help teams examine pipelines and associated equipment in industrial facilities. Camera-based pipe crawlers collect visual information inside accessible piping, while magnetic ultrasonic crawlers support thickness and corrosion inspection on suitable ferrous surfaces.
The inspection method should match the asset, access conditions, and information required.
3. Storage Tanks and Pressure Vessels
Magnetic ultrasonic crawlers can support remote thickness measurement and corrosion inspection on steel tank walls, roofs, and other suitable vessel surfaces. Encoded scanning systems help collect position-referenced inspection data.
Other remotely operated crawlers support visual inspection and cleaning workflows in tanks, depending on their configuration and attachments. For submerged tank work, see how underwater ROVs handle tank inspection.
4. Power Generation and Industrial Utilities
Power plants and utilities use crawlers on assets that are hard to reach or unsafe to enter. Examples include the Pipe Trekker A-150 for cooling pipes, the Deep Trekker ONYX UGV for hydroelectric turbines and water conduits, the DT640 for cooling systems, and the Endo Control CRAB-ROBOT for HVAC ducts. Magnetic UT crawlers such as the JIREH TRIPOD are also used in power generation for weld and corrosion inspection.
5. Confined Spaces and Water Infrastructure
Ground robots and amphibious crawlers can provide remote access to certain confined spaces, underground infrastructure, water tanks, and submerged structures. Depending on the platform, they may collect visual information, support cleaning tasks, or carry specialized inspection attachments.
Learn more about MFE’s confined space inspection solutions.
Buying vs. Renting a Crawler Robot
Whether to rent or own a crawler robot depends on how frequently your team performs inspections, how specialized the required equipment is, and whether you need the system for a specific project or ongoing operations.
Renting can be a practical option for project-based inspections, occasional shutdown work, or applications that require a specialized crawler. Ownership may make more sense when inspection work is recurring and the equipment will be used regularly.
Consider the inspection frequency, equipment configuration, operator familiarity, and support requirements before making a decision. Explore MFE’s ROV and crawler equipment to learn more about the available equipment categories.
Crawler Robot FAQ
What is a crawler robot?
A crawler robot is a remotely operated inspection platform designed to move through or across environments that may be difficult for people to access. Crawler robots collect information using cameras, ultrasonic testing equipment, or other supported inspection instruments. Common applications include pipe and sewer inspections, steel tank and vessel inspections, and remote inspection of confined industrial spaces.
What is a pipe crawler?
A pipe crawler is a robotic inspection system designed to travel inside pipes and pipelines. Most pipe crawlers use wheels or tracks and carry cameras that transmit footage to an operator outside the pipe. Depending on the model, they may support different pipe diameters, camera configurations, tether arrangements, and operating environments.
Pipe inspection robots are used in municipal sewer systems, stormwater infrastructure, industrial piping, and other pipeline applications.
What is the difference between a crawler robot and a push camera?
A crawler robot is a motorized inspection platform that travels through a pipe using wheels or tracks. A push camera is advanced through a pipe using a manually pushed cable.
Crawler robots can be useful for longer or more demanding inspections where remote movement, controlled navigation, and a motorized camera platform are beneficial. Push cameras can be a simpler option for shorter inspections or smaller pipes where a crawler is unnecessary.
The appropriate choice depends on pipe diameter, inspection distance, access conditions, and the information the inspection team needs to collect. See MFE’s push camera systems for an alternative inspection approach.
Can crawler robots work underwater?
Yes. Some crawler robots are designed for underwater operation, but this capability depends on the specific model and its depth rating.
For example, the Deep Trekker DT340 is depth rated to 50 meters (164 ft), and the DT300 Series Package includes submersible cameras. The Deep Trekker ONYX UGV is also described as fully submersible. Not every crawler is: the JIREH TRIPOD magnetic crawler is dust-tight and watertight but not submersible.
Always check the manufacturer’s specifications for the particular crawler and configuration before using it underwater.
Can a crawler robot measure wall thickness?
Yes. Certain magnetic crawler systems support ultrasonic testing (UT) for measuring material thickness and assessing corrosion on suitable ferrous surfaces.
For example, the MFE HPX Wall Crawler supports ultrasonic thickness inspection and encoded B-scan applications. The JIREH TRIPOD Magnetic Crawler can carry ultrasonic probes for thickness measurement, corrosion mapping, and weld inspection. The MFE HSR Crawler is a high-speed raster ultrasonic scanner designed for large vessel inspections.
These systems are different from camera-based pipe inspection crawlers: they collect ultrasonic inspection data rather than relying solely on visual footage.
 English
 English (Canada)
 Français du Canada